Skip to content
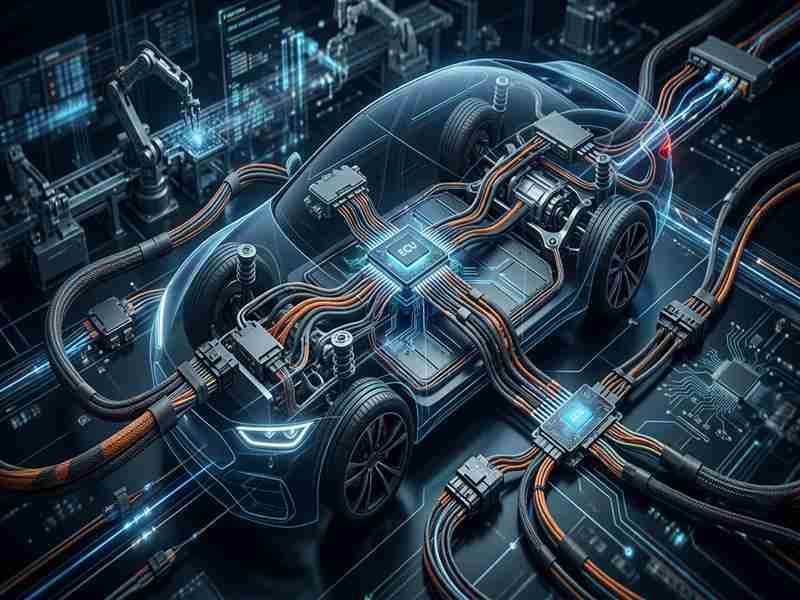
Automotive wiring is moving through one of its biggest architectural changes in decades. The harness is no longer treated only as a passive bundle connecting ECUs, sensors, switches, lamps, motors, and power loads. As vehicles add centralized computing, ADAS, high-resolution cameras, software-defined functions, and heavier electrical loads, the physical network has become an architectural decision. Where a controller sits, how many zones a platform uses, what voltage is distributed, and which network carries data can now change hundreds of individual circuits before a wire is ever cut.
Automotive zonal wire harness trends are moving toward shorter localized wiring, zone control units, centralized computing, higher-speed Ethernet backbones, mixed 12V/48V distribution, smarter electronic power switching, compact hybrid connectors, and more modular harness manufacturing. The goal is not simply to remove wire. It is to build an electrical architecture that is lighter, easier to scale, easier to automate, and better suited to software-defined vehicles.
A useful way to picture the change is to imagine a conventional vehicle harness laid out on a full-size assembly board, with long branches running from one end of the car to the other because different functions belong to different control domains. Now imagine many of those local devices stopping at a nearby zone controller instead, while a smaller number of backbone links carry data and power between zones. The final harness may still be complex, but the complexity has moved. Understanding where it moves is the key to understanding the next generation of automotive interconnect design.

What Is an Automotive Zonal Wire Harness?
An automotive zonal wire harness groups electrical connections mainly by physical location in the vehicle. Nearby sensors, actuators, switches, communication devices, and power loads connect to a local zone controller, while higher-level communication runs through shared backbone links. Compared with traditional domain-based wiring, this approach can reduce long wire runs, simplify routing, improve modularity, and support increasingly centralized vehicle computing.
Zonal Architecture Basics
Traditional automotive electrical systems grew around individual functions. Body electronics, infotainment, powertrain, chassis, safety, and ADAS functions were commonly handled by separate ECUs or domain controllers. The arrangement is logical from a software and functional perspective, but it can be inefficient physically because devices located next to one another may belong to completely different electronic domains. A rear lamp, parking sensor, door switch, seat module, and temperature sensor can therefore send separate harness branches toward different control units even though all five devices occupy the same area of the vehicle.
Zonal architecture changes the starting question from “which function owns this device?” to “where is this device physically located?” Devices in the front, rear, roof, cabin, or side areas can connect first to the nearest Zone Control Unit, or ZCU. Software running elsewhere in the vehicle can still use the information, but the long physical connection is replaced by a short local link plus a shared network backbone. This distinction separates physical I/O placement from software function placement, which is increasingly important as vehicle software becomes centralized and hardware platforms are expected to support more features over longer product lifecycles.
Domain vs Zonal Wiring
Domain architecture and zonal architecture solve different organizational problems. Domain architecture groups electronics by function, while zonal architecture groups physical connections by location. A body domain controller may manage lighting and access functions, while an ADAS controller handles cameras and radar. In a zonal design, the devices may terminate at a local ZCU even when their software functions are processed by different central computers. The important point is that zonal design does not necessarily remove every domain concept; many production platforms will use transitional or mixed architectures for years.
| Architecture | Main Organization | Typical Harness Effect | Common Computing Model |
| Distributed ECU | Individual function or subsystem | Many dedicated point-to-point circuits | Many independent ECUs |
| Domain | Functional domain | Fewer controllers, but many long cross-vehicle runs remain | Domain controllers |
| Zonal | Physical vehicle area | Shorter local branches and fewer long device-level runs | ZCUs plus domain or central compute |
| Central-Zonal | Physical zones plus centralized software | Highest potential for harness consolidation | ZCUs plus high-performance central computers |
The practical engineering task is rarely to replace an entire legacy system in one step. More often, engineers must decide which functions can move into zones, which CAN or LIN networks should remain, which safety paths still require dedicated treatment, and which interfaces are ready for Ethernet or smarter power distribution. For harness development, that means the drawing can no longer be treated independently from the E/E architecture. Branch length, connector placement, network topology, and power strategy increasingly need to be reviewed together before the physical harness is frozen.
Zone Control Units
The ZCU is the physical concentration point that makes zonal wiring possible. Depending on the platform, it can aggregate digital and analog I/O, bridge CAN, LIN, and Ethernet traffic, control local loads, monitor voltage and current, support diagnostics, and participate in local power distribution. That makes the ZCU more than a simple network switch. It is often where data communication, local control, and power management meet, so the harness interface around the ZCU becomes one of the most demanding connection areas in the vehicle.
A modern ZCU may need small-signal terminals, higher-current outputs, multiple grounds, CAN and LIN pairs, Single-Pair Ethernet, high-speed differential links, shielded or coaxial channels, and diagnostic circuits in a compact space. The overall harness may become shorter, but each ZCU connector can become denser and more multifunctional. Terminal retention, thermal loading, pin assignment, sealing, shielding, keying, serviceability, and automated insertion therefore become more important. Zonal architecture simplifies one layer of the vehicle while concentrating more responsibility into fewer interfaces, which is why connector and harness engineering need to evolve with the architecture rather than simply follow it.

How Is Zonal Architecture Changing Wire Harnesses?
Zonal architecture changes automotive wire harnesses by replacing many long device-to-controller runs with shorter local branches connected to nearby zone controllers. The main effects are lower copper length, reduced harness weight, simpler routing, smaller regional harness modules, and better platform reuse. The largest gains appear when topology, power distribution, connectors, and vehicle packaging are redesigned together instead of being optimized as separate systems.
Shorter Wire Runs
The most visible benefit comes from reducing unnecessary distance. If ten devices in the rear of a vehicle each need an average four-meter connection to different remote controllers, their combined device-level wiring is roughly 40 meters before counting shared conductors, shielding, loops, service slack, and routing detours. If those devices instead connect to a nearby rear ZCU with average one-meter local branches, the endpoint portion falls to about 10 meters, while a smaller number of shared backbone connections carry information and power upstream. The exact saving in a real vehicle depends on topology, but the mechanism is straightforward.
Wire reduction also removes more than copper. Every long branch may require insulation, tape, sleeves, conduit, clips, grommets, labels, seals, support points, and assembly space. Shortening a circuit can therefore reduce several secondary materials and operations at once. The packaging benefit is especially valuable in crowded areas such as instrument panels, floor tunnels, pillars, doors, roof structures, battery zones, and front-end modules. When fewer circuits cross these regions, designers gain more freedom for thermal systems, interior packaging, structural components, and service access, while assembly workers handle fewer long, awkward branches.
Weight and Copper Reduction
Harness weight matters because copper is dense and modern vehicles contain a large number of circuits. Zonal design can reduce weight first by shortening conductors and second by enabling other architectural changes such as higher distribution voltage, shared communication networks, localized switching, and common interfaces. A shorter 12V circuit may save material, but a redesigned 48V feeder that carries the same power at one-quarter of the current can open a much larger conductor-sizing opportunity when temperature rise, voltage drop, and terminal limits allow it.
The percentage saved will never be universal. Vehicle length, number of zones, safety redundancy, option content, electrical load, connector density, and the amount of legacy architecture retained all affect the result. A platform that adds ZCUs but leaves most long point-to-point wiring in place may achieve only modest savings. A clean-sheet central-zonal platform can do much more because computing, networking, power, and routing are optimized together. When public reports cite large harness-weight reductions, they should therefore be read as vehicle-specific program outcomes rather than a fixed rule that applies to every zonal design.
Packaging and Modular Harnesses
Conventional main harnesses can become very large three-dimensional assemblies. They are difficult to manufacture, transport, store, install, and modify because hundreds of branches need to reach precise physical locations. Zonal architecture creates an opportunity to divide that structure into regional modules. A front-zone harness can serve lighting, front sensors, pumps, fans, thermal equipment, and local actuators, while a roof-zone harness can focus on cameras, antennas, microphones, lighting, and roof controls. Rear and cabin zones can be organized around their own local devices and mounting points.
Smaller regional modules can improve assembly because each harness has a clearer physical boundary and a more predictable installation sequence. Modularity also helps platform development: multiple vehicle variants may share the same central compute and ZCU architecture while changing only selected local harnesses. The trade-off is configuration management. More modularity can create more variants if cavity populations, branch lengths, connector orientations, labels, or option circuits are not standardized. Strong programs therefore rely on controlled part numbers, drawings, BOM revisions, cavity maps, test definitions, and traceability so physical simplification does not create uncontrolled documentation complexity.

Which Data Networks Are Shaping Zonal Harnesses?
Automotive Ethernet is becoming the main high-bandwidth backbone for zonal architectures, while CAN and LIN continue to handle many established control functions. Single-Pair Ethernet is also extending Ethernet closer to sensors and actuators. Future zonal harnesses will therefore combine several network technologies, selected according to bandwidth, latency, cost, safety, cable length, electromagnetic environment, and the type of device being connected.
Automotive Ethernet
A zonal architecture needs shared communication links because local I/O must communicate with central or distributed computing resources. If every camera, sensor, actuator, and controller still required an independent long cable, the physical value of zoning would disappear. Automotive Ethernet provides a scalable path from lower-speed edge communication to multi-gigabit backbone links, but the engineering challenge is choosing the right physical layer for the job rather than using the fastest interface everywhere.
| Network | Nominal Data Rate | Typical Zonal Role | General Cable Consideration |
| 10BASE-T1S | 10 Mb/s | Edge sensors, actuators, local control | Single balanced pair; multidrop possible |
| 100BASE-T1 | 100 Mb/s | Control, cameras, infotainment, gateways | Automotive single-pair differential link |
| 1000BASE-T1 | 1 Gb/s | Higher-bandwidth ECU and backbone links | Controlled impedance and channel performance |
| 2.5/5/10GBASE-T1 | 2.5-10 Gb/s | High-performance backbone and compute links | Tight SI, connector, shielding, and insertion-loss control |
| CAN / CAN FD | Application dependent | Control, diagnostics, established ECU networks | Mature twisted-pair architecture |
| LIN | Up to about 20 kb/s | Low-cost local actuators and controls | Simple single-wire network |
The data-rate table also shows why the future vehicle network is unlikely to become a single-protocol system. A window motor does not need a 10 Gb/s link, while a high-resolution camera or central compute backbone may require far more bandwidth than a traditional control bus can provide. The more useful design question is which interface provides sufficient performance with reasonable cost, EMC margin, connector complexity, and software support. ZCUs are well placed to bridge these layers, allowing several mature networks to coexist while higher-bandwidth communication moves onto Ethernet where it brings a real system benefit.
Single-Pair Ethernet
Single-Pair Ethernet is particularly relevant because it can extend Ethernet toward the vehicle edge without requiring the cabling structure associated with conventional office Ethernet. 10BASE-T1S operates at 10 Mb/s and can support multidrop topologies, making it suitable for lower-bandwidth sensors and actuators that can benefit from an Ethernet-based communication environment but do not justify dedicated high-speed switched ports. This can reduce gateway count and support a more unified diagnostic and software architecture, especially when a zone contains many small devices that currently depend on several different local buses.
The technology does not remove the need for careful physical design. Engineers still need to define segment length, topology, node count, connector transitions, shielding or unshielded implementation, EMC limits, and routing near switching power circuits. CAN and LIN will also remain important because they are mature, cost-effective, and deeply integrated into automotive control systems. During the transition, many ZCUs will act as protocol-consolidation points where Ethernet, CAN, LIN, discrete I/O, and local power meet. The trend is therefore not “Ethernet replaces everything,” but “Ethernet moves closer to the edge while legacy networks remain where they still make engineering and economic sense.”
Signal Integrity and EMI
As data rates increase, continuity testing becomes only the first step. A cable can show perfect pin-to-pin continuity and still fail as a high-speed channel because differential impedance is wrong, skew is excessive, shielding is poorly terminated, or a connector transition creates too much discontinuity. Pair geometry, twist, conductor spacing, shield coverage, ground return, cable length, bend state, and routing near high-current switching circuits all become part of the electrical performance of the channel rather than optional manufacturing details.
Validation can include TDR, insertion loss, return loss, BER testing, network analysis, or system-level functional tests depending on the interface and customer specification. Zonal architecture makes this more important because high-speed communication and switched power can converge around the same ZCU. Adding more shield is not automatically the best solution if the termination is poor, and moving a sensitive pair away from a switching conductor can sometimes provide more benefit than increasing braid coverage. For custom programs, SINO-CONN can review cable structure, connector transitions, grounding, shielding, and test requirements together so the physical assembly is designed around the real channel rather than around continuity alone.
How Are 48V Systems Changing Zonal Power Distribution?
48V systems can deliver the same electrical power at roughly one-quarter of the current required by a 12V system. Lower current can reduce conductor size, copper weight, voltage drop, and thermal loss. In zonal vehicles, 48V distribution can be combined with local DC-DC conversion and intelligent switching, allowing higher-power loads and traditional 12V devices to coexist within one architecture while shortening high-current feeder circuits.
Current and Copper Demand
The attraction of 48V starts with the basic relationship P = V x I. For a given power level, increasing voltage reduces current. A 1.2 kW load ideally draws 100A at 12V but only 25A at 48V, before real-world conversion losses and operating-voltage variation are considered. Because conductor heating is strongly related to current, reducing current creates room to use smaller conductors when voltage-drop, temperature-rise, terminal, duty-cycle, and safety requirements permit. The benefit becomes increasingly important as vehicles add electric pumps, fans, heaters, chassis actuators, computing hardware, and other higher-power loads.
| Load Power | Current at 12V* | Current at 48V* | Current Reduction |
| 500 W | 41.7 A | 10.4 A | 75% |
| 1,000 W | 83.3 A | 20.8 A | 75% |
| 2,000 W | 166.7 A | 41.7 A | 75% |
| 3,000 W | 250.0 A | 62.5 A | 75% |
Ideal calculation before conversion losses and real operating-voltage variation.
The numbers are useful, but current alone never determines wire size. Ambient temperature, bundle derating, insulation class, conductor material, allowable voltage drop, terminal current rating, connector temperature rise, duty cycle, installation method, and customer safety rules all affect the final selection. This is where a cable assembly manufacturer needs to do more than follow an AWG copied from an early concept drawing. The operating current, peak current, conductor length, terminal system, thermal environment, and protection strategy should be reviewed together before a production wire size is locked.
12V and 48V Together
The move toward 48V does not mean 12V disappears. The automotive supply chain contains an enormous installed base of sensors, ECUs, lighting modules, actuators, relays, infotainment electronics, and accessories designed around established 12V ecosystems. Requalifying every component at once would add cost and risk with little benefit for low-power functions. A more practical zonal architecture distributes 48V where the higher voltage brings a clear advantage, then converts locally to 12V for devices that still require it.
Local conversion can reduce the length of high-current 12V feeder circuits because 48V travels farther through the vehicle at lower current before a ZCU or nearby power module performs the conversion. This makes circuit identification and documentation more important. The same connector area may include 48V feeders, 12V outputs, grounds, switched loads, and communication channels. Conductor sizing, terminal selection, cavity assignment, fuse or electronic-protection strategy, labeling, and service documentation must be controlled carefully so mixed-voltage systems remain safe and understandable throughout manufacturing, vehicle assembly, maintenance, and future design changes.
Smart Power Distribution
Traditional automotive power distribution relies heavily on centralized fuse boxes, mechanical relays, and long individual feeder circuits. Zonal systems allow some of that responsibility to move closer to the load through electronic switching and monitoring. Smart high-side or low-side devices can provide current measurement, overload protection, diagnostics, reset capability, and software-controlled load management. The vehicle can therefore do more than simply open a fuse when a fault occurs; it can identify abnormal current, isolate selected loads, record diagnostics, and apply power-state strategies based on operating conditions.
The harness benefit comes from topology. A higher-capacity feeder can supply a zone, and local electronics can distribute power to nearby loads, reducing the need for many separate long wires back to a central box. Power and data also become more closely linked because a ZCU can receive network commands, switch a load, measure current, and report status through Ethernet or another vehicle bus. This convergence raises new connector questions around thermal spacing, ground strategy, EMC, current density, terminal selection, sealing, and service access, especially when power and sensitive data share the same module or connector region.
How Are Zonal Harness Design and Manufacturing Changing?
Zonal harness design is moving toward smaller regional assemblies, higher-density connectors, hybrid power-and-data interfaces, greater terminal commonization, and structures that are easier to automate. Manufacturing is also becoming more platform-oriented. Instead of treating the complete vehicle harness as one highly customized object, OEMs can increasingly manage repeatable zone modules with controlled variants across several vehicle programs and option levels efficiently.
Modular and Hybrid Connectors
Zone controllers concentrate more functions into fewer electronic nodes. A single ZCU interface may therefore need small signal terminals, medium-current power outputs, differential data pairs, coaxial channels, grounds, and diagnostics within a compact area. Using a separate connector for every function can consume PCB edge space and increase mating operations, while a well-designed modular or hybrid system can combine several terminal types inside a common mechanical interface. This is one reason connector modularity has become closely associated with central-zonal E/E architectures.
The engineering challenge is density. Putting more power and high-speed data into the same physical region increases the need to control temperature rise, crosstalk, shield continuity, terminal retention, keying, sealing, and repair access. A smaller connector is useful only when it remains robust under vibration, temperature, fluid exposure, and repeated manufacturing handling. For sourcing teams, modularity can also improve commonization, but compatible-looking parts should not be assumed to be interchangeable. Exact housing, terminal, seal, mating, current, signal, and environmental requirements still need to be checked at the full part-number level before any connector alternative is approved.
Automation-Friendly Harnesses
Wire harness manufacturing remains difficult to automate because flexible wires do not behave like machined components. Branches move, tapes and sleeves deform, connector orientations vary, and a large vehicle harness can cover several square meters on an assembly board. Zonal architecture does not remove these challenges, but smaller regional harnesses can be more automation-friendly when designers standardize wire lengths, connector families, terminal insertion directions, cavity-loading sequences, fixture locations, and test access. The design itself starts to influence how much of the production process can be automated.
The opportunity is usually gradual rather than a sudden move to a fully automated harness factory. Cutting, stripping, crimping, seal loading, wire marking, continuity testing, cavity verification, and some connector insertion operations can be automated more readily when the product is repeatable. Complex taping, irregular branch formation, soft-material handling, and variant management may still require manual work. The quality benefit can be as important as labor savings because standardized or automated operations reduce operator-dependent variation and make production data easier to capture. For volume programs, DFM discussions should therefore include terminal access, splice location, branch geometry, testability, labeling, and variant commonization before drawings are frozen.
Platform-Based Harness Design
Zonal architecture encourages OEMs to think in reusable vehicle platforms rather than isolated harness projects. If several models share central computing, four or six ZCU positions, backbone interfaces, and common connector families, much of the electrical architecture can remain stable even when body dimensions and option content change. A sedan, crossover, and SUV may use related front-zone electronics while adapting selected rear, roof, door, seat, or camera harnesses to suit different packaging and feature levels.
This platform approach creates opportunities for family BOMs, common connector and terminal systems, shared wire specifications, common inspection criteria, standard labels, and reusable test fixtures. The risk is variant explosion. A modular architecture can still become difficult to control if hundreds of nearly identical harness versions are created without disciplined part numbering and change management. The strongest platform strategy is therefore not the one with the most modules; it is the one that maximizes common architecture while limiting regional variation to what the vehicle genuinely needs. Revision control, cavity maps, labels, packaging identification, and traceability become essential parts of the engineering system rather than paperwork added after development.
What Must OEMs Validate for Future Zonal Harnesses?
Future zonal harnesses must be validated as electrical, signal, mechanical, environmental, manufacturing, and supply-chain systems rather than checked only for continuity. Validation should cover power capacity, voltage drop, crimp quality, high-speed channel performance, EMI, connector retention, vibration, temperature, sealing, routing, traceability, and controlled revisions. The exact plan depends on the vehicle function, risk level, customer specification, and required automotive documentation.
Electrical and Signal Validation
A low-speed switch wire, a 30A actuator circuit, a CAN pair, and a multi-gigabit Ethernet link have different failure modes and should not receive the same test plan. Power circuits need conductor sizing, terminal capacity, voltage drop, resistance, temperature rise, duty cycle, and protection review. High-speed links additionally require attention to impedance, connector transition, pair geometry, insertion loss, return loss, skew, and channel performance. The most useful validation plan starts with the function of each circuit and then assigns the test method that can actually reveal the relevant risk.
Typical production and development controls can include 100% pin-to-pin continuity, open/short detection, insulation resistance where specified, conductor and connector resistance, voltage-drop checks, crimp-height verification, terminal pull tests, crimp cross-section analysis, TDR, insertion loss, return loss, BER, or system functional testing. Not every project needs every test. VNA testing on a simple 12V switch harness would add cost without meaningful value, while continuity alone is inadequate for a multi-gigabit channel. The discipline is to connect each test to a defined requirement and acceptance limit, then make sure the requirement survives from drawing and prototype through pilot and mass production.
Mechanical and Environmental Validation
A harness can pass every bench electrical test and still fail in the vehicle if installation conditions are poorly understood. A connector can partially unmate under vibration, a branch can rub against a bracket, a wire can bend repeatedly at the connector exit, or water can enter through a seal that does not match the cable diameter. Mechanical reliability therefore begins with the actual routing path, mounting points, connector orientation, service access, strain relief, clip locations, bend radius, abrasion risk, and movement expected during vehicle operation and assembly.
Environmental requirements should also stay application-specific. A cabin harness, door harness, engine-bay assembly, battery-area cable, underbody connection, and roof module do not face the same temperature, fluid, sealing, or vibration conditions. Automotive harness review commonly includes terminal retention, CPA or TPA features where used, connector locking, pull-force expectations, fluid exposure, temperature range, water ingress, thermal proximity, and repeated motion. SINO-CONN’s automotive development approach treats routing, connector and terminal definition, temperature, vibration, EMI/grounding, traceability, and project documentation as design inputs that need confirmation rather than assumptions applied after the sample has been built.
Prototype to Production
A robust zonal harness program should move through controlled engineering stages rather than jump directly from a concept into volume manufacturing. A practical path is Requirement -> Engineering Review -> Drawing and BOM -> Prototype -> Validation -> Pilot Build -> Production Release -> Repeat Supply. The first prototype confirms fit, pinout, connector mating, routing, wire length, shielding, and basic electrical function. The pilot stage has a different purpose: it checks whether near-production materials, tooling, work instructions, fixtures, tests, labels, packaging, and inspection points can reproduce the approved design consistently.
Before quoting or developing a complex zonal harness, the most useful information usually includes the main harness drawing, branch dimensions, connector and terminal part numbers, mating details, cavity map, wire list, AWG, operating and peak current, network protocol, data rate, shielding, grounding, mounting points, temperature, vibration, sealing, annual volume, schedule, and required documentation. Automotive programs may also require customer-specific PPAP-related records, control plans, material declarations, inspection reports, traceability, or change approvals. SINO-CONN supports projects that begin with drawings, BOMs, pinouts, samples, or defined requirements and can carry the approved configuration through prototype, validation, pilot, and controlled production without treating the sample itself as the only production standard.
The most important automotive zonal wire harness trend is not a single cable type, connector family, voltage level, or network protocol. It is the move toward treating electrical distribution, data communication, mechanical packaging, manufacturing, and software architecture as one connected system. Shorter local harnesses, ZCUs, Ethernet backbones, mixed 12V/48V power, smart switching, hybrid connectors, and modular manufacturing all reinforce one another. When these decisions are made together, the harness can become lighter, easier to route, more scalable, and more compatible with future software-defined vehicle platforms.
For engineering teams, that means harness development needs to start earlier and with better information. Connector availability, current capacity, voltage drop, signal integrity, shielding, bend paths, sealing, terminal systems, test methods, and production controls should be discussed before drawings are frozen, not after a vehicle package is already locked. A manufacturer that can translate electrical and mechanical requirements into a controlled drawing, prototype, validation plan, and repeatable production process can help reduce late-stage changes without turning a technical article into a sales pitch. The strongest evidence of capability is still a harness that fits, performs, survives its environment, and can be built the same way again.
FAQ
What is the difference between zonal and domain automotive architecture?
Domain architecture groups electronics by function, such as body, chassis, infotainment, or ADAS, while zonal architecture groups physical connections by vehicle location. A rear sensor can therefore connect to a rear ZCU even if the software using that sensor runs in a central computer or another functional domain. Zonal design mainly reduces physical wiring distance and supports centralized computing, while domain design mainly organizes functional control. Many new vehicles will use hybrid structures that combine both approaches during the transition.
How does zonal architecture reduce automotive wire harness weight?
Zonal architecture reduces weight by shortening long point-to-point circuits and replacing some of them with local branches connected to nearby ZCUs. Less cable length means less copper, insulation, tape, conduit, clips, and other support materials. Additional savings may come from shared data backbones and higher-voltage power distribution, which can reduce conductor size for some loads. The final percentage depends on vehicle size, number of zones, option content, redundancy, power strategy, and how much legacy wiring remains in the platform.
Will Automotive Ethernet replace CAN and LIN in zonal vehicles?
Automotive Ethernet is likely to carry more backbone and higher-bandwidth traffic, but CAN and LIN will remain useful for many control functions because they are mature, cost-effective, and widely supported. Zonal controllers can bridge Ethernet, CAN, LIN, and discrete I/O, allowing each technology to be used where it makes technical and economic sense. Over time, Single-Pair Ethernet may move closer to low-speed sensors and actuators, but a complete replacement of CAN and LIN across every vehicle function is neither necessary nor likely in the near term.
Why is 48V power distribution important for zonal wire harnesses?
For the same power, 48V requires one-quarter of the current needed at 12V in an ideal calculation. A 1,000W load draws about 83.3A at 12V but only about 20.8A at 48V. Lower current can reduce conductor cross-section, copper weight, voltage drop, and heat when terminal, insulation, temperature, and safety requirements permit. Zonal architectures can distribute 48V to regional nodes and convert locally to 12V, shortening high-current 12V feeders without forcing every vehicle component to change voltage at once.
What should be tested on a high-speed zonal harness?
High-speed zonal harnesses need more than continuity testing. The validation plan may include differential impedance, TDR, insertion loss, return loss, skew, shield termination, grounding, connector-transition performance, BER, and system-level communication tests, depending on the protocol and customer requirement. Mechanical factors such as bend state, connector locking, routing near high-current switching circuits, vibration, and temperature can also influence signal performance. The correct test set should be linked to defined channel requirements rather than applied as a generic checklist to every cable.
What information is needed to develop a custom automotive zonal harness?
A strong RFQ or development package should include the harness drawing or system layout, branch dimensions, connector and terminal part numbers, pinout, wire list, AWG, operating and peak current, network protocol, data rate, shielding and grounding requirements, mounting points, temperature, vibration, sealing conditions, annual volume, target schedule, and documentation needs. If the design is incomplete, a physical sample, interface information, or functional requirement can still start engineering review, but the project should be converted into controlled drawings, BOMs, pin maps, and acceptance criteria before production.